Perception
Adapted BlazePose for markerless shoulder and elbow tracking from an iPhone camera.
Imperial College London · 2024–2025
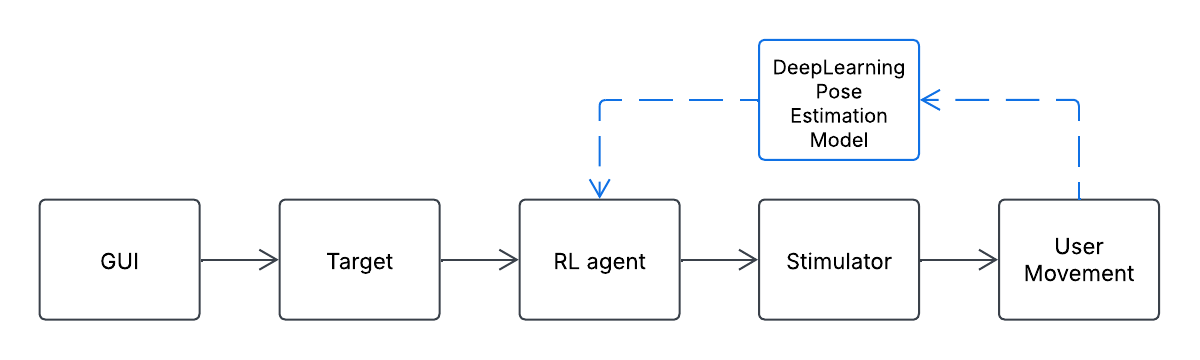
A camera-based movement feedback layer for a pre-existing reinforcement-learning-controlled functional electrical stimulation system.
01 · The challenge
The controller needs joint-angle feedback without the setup burden of a marker-based motion-capture system.
I compared ten pose-estimation approaches, selected and adapted BlazePose, then converted its landmarks into shoulder and elbow angles using vector calculus.
The camera pipeline was integrated into the existing interface so the controller could receive frames, angles and angular velocities during operation.
02 · My contribution
Adapted BlazePose for markerless shoulder and elbow tracking from an iPhone camera.
Tested four participants outside the lab and four participants against a goniometer reference in the lab.
Connected the movement signal to the existing RL-FES interface and a portable hardware prototype.
Evaluation snapshot
The markerless pipeline held approximately 25 FPS outside the lab. Joint-angle error stayed below 3° for much of the tested range, with larger errors at biomechanical limits.
This was a small research prototype evaluated with four participants per study, not a medical device or clinical treatment system.
Signal Mode disabled.